Eigen-Contrib  5.0.1
 
Loading...
Searching...
No Matches
Eigen::LookAheadLevinson< Scalar_ > Class Template Reference

#include <contrib/Eigen/src/StructuredMatrices/LookAheadLevinson.h>

Detailed Description

template<typename Scalar_>
class Eigen::LookAheadLevinson< Scalar_ >

Look-ahead Levinson direct solver for general Toeplitz systems.

Solves T*x = b for a square Toeplitz matrix T in O(n^2) operations. This is an implementation of the look-ahead Levinson algorithm of T. F. Chan and P. C. Hansen, which extends the classical Levinson recursion to remain (weakly) numerically stable for general — including indefinite and ill-conditioned — Toeplitz matrices. When the recursion would otherwise break down at a near-singular leading principal submatrix, the algorithm "looks ahead" and takes a block step (up to maxBlockSize) over it. As a by-product it produces an estimate of the matrix condition number (conditionEstimate).

The class derives from SolverBase and follows the usual decomposition style; transposed and adjoint systems reuse the factorization of T through the persymmetry \( T^T = E T E \) (with E the exchange matrix), so all three solves below cost the same:

LookAheadLevinson<double> levinson(T); // or levinson.compute(T);
VectorXd x = levinson.solve(b); // solve T * x = b
VectorXd y = levinson.transpose().solve(b); // solve T^T * y = b
VectorXd z = levinson.adjoint().solve(b); // solve T^H * z = b
LookAheadLevinson()
Definition LookAheadLevinson.h:93
Matrix< double, Dynamic, 1 > VectorXd
Template Parameters
Scalar_the scalar type, real or complex.

References:

  • T. F. Chan and P. C. Hansen, "A look-ahead Levinson algorithm for general Toeplitz systems," IEEE Trans. Signal Process., 40(5):1079-1090, 1992.
  • T. F. Chan and P. C. Hansen, "A look-ahead Levinson algorithm for indefinite Toeplitz systems," SIAM J. Matrix Anal. Appl., 13(2):490-506, 1992.
See also
class Toeplitz
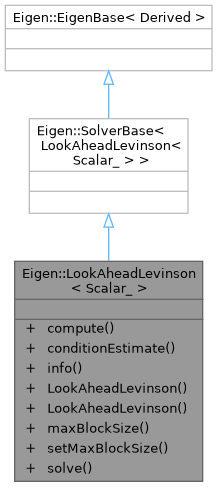
+ Inheritance diagram for Eigen::LookAheadLevinson< Scalar_ >:

Public Member Functions

template<int Rows_, int Cols_>
LookAheadLevinson & compute (const Toeplitz< Scalar, Rows_, Cols_ > &T)
 
RealScalar conditionEstimate () const
 
ComputationInfo info () const
 
 LookAheadLevinson ()
 
template<int Rows_, int Cols_>
 LookAheadLevinson (const Toeplitz< Scalar, Rows_, Cols_ > &T)
 
Index maxBlockSize () const
 
LookAheadLevinson & setMaxBlockSize (Index p)
 
template<typename Rhs>
const Solve< LookAheadLevinson, Rhs > solve (const MatrixBase< Rhs > &b) const
 

Constructor & Destructor Documentation

◆ LookAheadLevinson() [1/2]

template<typename Scalar_>
Eigen::LookAheadLevinson< Scalar_ >::LookAheadLevinson ( )
inline

Default constructor; call compute before solve.

◆ LookAheadLevinson() [2/2]

template<typename Scalar_>
template<int Rows_, int Cols_>
Eigen::LookAheadLevinson< Scalar_ >::LookAheadLevinson ( const Toeplitz< Scalar, Rows_, Cols_ > & T)
inlineexplicit

Constructs and factorizes from the Toeplitz matrix T, which may have fixed or dynamic dimensions.

Member Function Documentation

◆ compute()

template<typename Scalar_>
template<int Rows_, int Cols_>
LookAheadLevinson & Eigen::LookAheadLevinson< Scalar_ >::compute ( const Toeplitz< Scalar, Rows_, Cols_ > & T)

Factorizes the square Toeplitz matrix T.

See also
solve

◆ conditionEstimate()

template<typename Scalar_>
RealScalar Eigen::LookAheadLevinson< Scalar_ >::conditionEstimate ( ) const
inline
Returns
an estimate of the 2-norm condition number of T, available after compute (the "algorithm condition number" of Chan and Hansen).

◆ info()

template<typename Scalar_>
ComputationInfo Eigen::LookAheadLevinson< Scalar_ >::info ( ) const
inline
Returns
Success if the algorithm could skip all ill-conditioned leading submatrices within the look-ahead range, NumericalIssue otherwise.

◆ maxBlockSize()

template<typename Scalar_>
Index Eigen::LookAheadLevinson< Scalar_ >::maxBlockSize ( ) const
inline
Returns
the maximum look-ahead block size \( p_{\max} \).
See also
setMaxBlockSize

◆ setMaxBlockSize()

template<typename Scalar_>
LookAheadLevinson & Eigen::LookAheadLevinson< Scalar_ >::setMaxBlockSize ( Index p)
inline

Sets the maximum look-ahead block size \( p_{\max} \) (default 4). The solver is numerically stable as long as T has no more than p-1 consecutive ill-conditioned leading principal submatrices. Must be called before compute.

◆ solve()

template<typename Scalar_>
template<typename Rhs>
const Solve< LookAheadLevinson, Rhs > Eigen::LookAheadLevinson< Scalar_ >::solve ( const MatrixBase< Rhs > & b) const
inline
Returns
the solution x of T*x = b, as a lazily evaluated expression. Supports multiple right-hand sides. The transposed and adjoint systems are solved at the same cost, and with the same factorization, through transpose().solve(b) and adjoint().solve(b).
Precondition
compute has been called.

The documentation for this class was generated from the following file: